A robotic arm can pass a static strength analysis and still have a serious mechanical design problem.
The structure may withstand the required payload. Stress may remain within acceptable limits. Static deflection may be manageable.
Then the robot starts moving at production speed.
The end effector begins to oscillate. Settling time increases. Position accuracy becomes inconsistent. A particular operating speed produces noticeably higher vibration. In some cases, the problem appears only after a heavier tool or payload is added.
These problems are often related to the dynamic behavior of the structure.
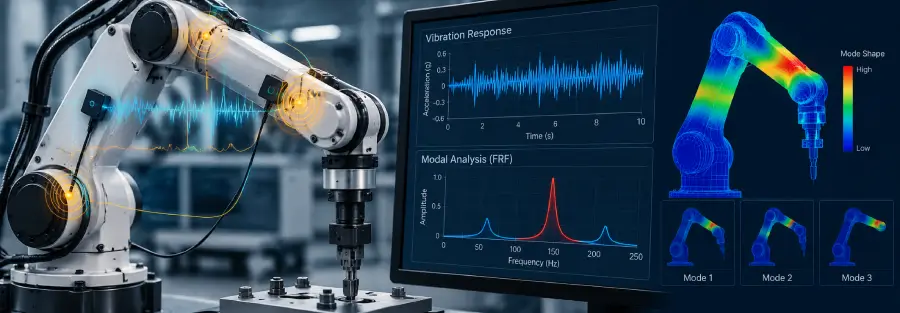
Robotic arm vibration analysis uses modal analysis and, where required, frequency-response analysis to identify natural frequencies, mode shapes and resonance risks before they become expensive hardware problems.
For robotics companies developing physical hardware, this analysis can be used during mechanical design to understand how arm geometry, stiffness, mass distribution, joints, payload and operating conditions affect dynamic performance.
Why robotic arms develop vibration problems?
A robotic arm is a flexible mechanical system made up of links, joints, actuators, bearings, gearboxes, brackets and an end effector.
Every part contributes to the overall mass and stiffness of the structure.
When the robot accelerates or decelerates, these components are subjected to dynamic forces. The resulting excitation can interact with the natural frequencies of the structure.
Vibration problems can become more noticeable when:
- The arm is lightweighted
- Reach is increased
- Payload is increased
- Motion speed is increased
- Acceleration or jerk is increased
- A heavier end effector is installed
- Joint stiffness is insufficient
- The robot is mounted on a flexible structure
- Motor or gearbox excitation overlaps with a structural mode
- A new operating configuration changes the dynamic characteristics
The problem is therefore not simply “too much vibration.”
The engineering question is:
Which part of the structure is participating in the vibration, at what frequency, under which operating condition, and what design change can move the system away from the problematic response?
That is where modal analysis becomes useful.
What is robotic arm modal analysis?
Modal analysis is a structural simulation method used to determine the natural frequencies and mode shapes of a mechanical system.
For an idealized undamped structural system, the dynamic problem can be represented by the mass and stiffness relationship:
[M]{ẍ} + [K]{x} = {F}
The resulting eigenvalue problem provides the natural frequencies and corresponding mode shapes.
For a robotic arm, these results can show whether important modes are dominated by:
- Arm-link bending
- Link torsion
- Joint deformation
- End-effector movement
- Base flexibility
- Bracket deformation
- Coupled motion across multiple links
The frequency alone is not enough.
A result such as “first natural frequency = X Hz” does not explain what should be changed.
The mode shape shows where the structure is moving and helps identify the physical part responsible for the dynamic behavior.
Published robotic-arm research commonly uses modal analysis to identify natural frequencies and mode shapes before investigating forced or harmonic response.
What is resonance in a robotic arm?
Resonance occurs when an excitation frequency approaches a natural frequency of the structure and produces a significantly amplified response.
For a robotic arm, excitation can originate from several sources.
Motor and gearbox excitation
Rotating components can introduce periodic excitation into the mechanical structure.
Depending on motor speed, gearing and operating conditions, these frequencies can interact with structural modes.
Joint motion
Rapid acceleration and deceleration create dynamic loading that does not exist in the same form during a stationary payload condition.
A robot can therefore pass a static load case and still experience excessive vibration during motion.
Payload and end-effector mass
Adding a tool, gripper or payload changes the mass distribution of the robot.
This can shift natural frequencies and change the corresponding mode shapes.
Base excitation
The robot may also receive vibration through its mounting structure.
This matters when a robotic arm is installed on:
- A vehicle
- A mobile platform
- A production machine
- A flexible pedestal
- Another mechanical assembly
Research on long-reach robotic arms has demonstrated the use of measured base excitation together with modal and harmonic analysis to investigate vibration response.
Operating speed
A structural mode does not need to be permanently problematic.
A robot may operate normally through most of its speed range and show a large response only around a particular operating condition.
This makes operating-envelope analysis important.
Why static FEA is not enough for robotic arm vibration
Static FEA and modal analysis answer different engineering questions.
Static structural analysis can help determine:
- Stress
- Strain
- Static displacement
- Load paths
- Structural stiffness
- Areas requiring reinforcement
Modal analysis helps determine:
- Natural frequencies
- Mode shapes
- Dominant structural modes
- Potential resonance regions
A robotic arm therefore needs to be evaluated against both its strength requirements and its dynamic requirements when vibration is important.
Consider two arm designs with similar static stress and deflection.
One has a sufficiently high first natural frequency relative to its operating excitation.
The other has a structural mode close to a dominant excitation frequency.
Both may pass the static load case.
Their actual operating behavior can be very different.
This is why vibration analysis should be considered during robotic hardware development rather than treated only as a troubleshooting exercise after prototype testing.
How robotic arm vibration analysis is performed
A useful vibration study begins with the actual mechanical architecture.
The goal is not to create the most complicated simulation model possible.
The goal is to create a model that captures the structural characteristics responsible for the engineering problem.
1. Prepare the robotic arm CAD model
The starting point is normally the mechanical CAD assembly.
Depending on the analysis objective, unnecessary geometric details can be removed.
Features that have little influence on mass or stiffness may not need to be represented in full detail.
However, important structural features such as thin sections, mounting interfaces, joint housings and major brackets should be retained appropriately.
The model may include:
- Arm links
- Joint housings
- Actuators
- Gearbox masses
- Bearings
- Mounting brackets
- End effector
- Tooling
- Payload representation
Model simplification should preserve the mechanical behavior that matters to the vibration study.
2. Define material and mass properties
Modal behavior depends strongly on mass and stiffness.
Important inputs include:
- Young’s modulus
- Poisson’s ratio
- Density
- Material orientation for composite structures
- Concentrated masses
- Joint properties
- Connection stiffness where appropriate
This becomes particularly important for lightweight robotic arms.
Removing material changes the mass of the structure, but it can also reduce stiffness.
The resulting change in the stiffness-to-mass relationship can shift the natural frequencies.
This is one reason weight optimization and vibration analysis should be considered together rather than as independent design activities.
3. Represent joints and connections
The joints are a major part of a robotic arm’s mechanical behavior.
An analysis that assumes every connection is perfectly rigid may produce a different dynamic response from one that accounts for joint compliance.
Depending on the design and available data, the model may need to consider:
- Joint stiffness
- Bearing interfaces
- Gearbox stiffness
- Bolted connections
- Mounting compliance
- Actuator mass
- Structural contact behavior
The appropriate level of detail depends on the engineering question.
For early design screening, simplified representations may be sufficient.
For design validation, important joint and interface behaviour may need to be represented more accurately.
4. Apply realistic boundary conditions
Boundary conditions can have a major effect on modal results.
A robotic arm bolted to a rigid laboratory floor is not necessarily equivalent to a robot mounted on a flexible frame or vehicle.
If the mounting structure contributes to the lower modes, ignoring it can lead to an unrealistic prediction of dynamic behavior.
The analysis should therefore represent the actual mounting condition as closely as practical.
5. Perform modal analysis
The modal analysis provides the natural frequencies and corresponding mode shapes.
The results should then be reviewed physically.
For example, if the first mode is dominated by bending of a long arm link, increasing stiffness in that link may be a useful design direction.
If the mode is dominated by joint compliance, simply increasing link thickness may not solve the problem.
If the base is moving significantly, the mounting structure may need attention.
This is why the mode shape is as important as the frequency value.
6. Compare natural frequencies with operating excitation
The next step is to identify the frequencies that can excite the robot.
Potential sources include:
- Motor speed
- Gearbox frequency
- Joint operating frequency
- Motion cycles
- Repeated acceleration
- Base vibration
- Tool excitation
- Process-related forces
The objective is not to achieve one universal natural-frequency number.
There is no single frequency target that applies to every robotic arm.
The required dynamic margin depends on the robot architecture, operating speed, excitation characteristics, damping, control system and performance requirements.
When frequency-response analysis is needed
Modal analysis identifies the structural frequencies where resonance can occur.
It does not, by itself, describe the complete response of the robot under a specific excitation.
When the excitation is known, frequency-response or harmonic-response analysis can be used to investigate:
- Displacement amplitude
- Acceleration response
- Stress response
- Response amplification
- Sensitive frequency ranges
A published study of a 5-DOF long-reach robotic arm used modal analysis first and then transferred the modal results into harmonic analysis to evaluate the response to applied excitation.
Another robotic-arm study similarly used modal analysis followed by harmonic-response analysis to evaluate displacement and stress under vibration.
For a robotics company, this can answer a more practical question:
What will the arm actually do when it operates through its intended frequency range?
Robotic arm vibration problems that simulation can identify
A well-defined vibration analysis can investigate several common hardware problems.
Excessive end-effector oscillation
The structure may continue vibrating after a rapid movement, increasing settling time and affecting positioning performance.
Resonance at specific speeds
The response may become significantly larger within a particular operating-speed range.
Low first natural frequency
A lightweight or long-reach structure may not have enough stiffness for the intended operating envelope.
Joint or bracket flexibility
The dominant vibration may originate from a joint or support rather than the main arm link.
Payload-induced dynamic changes
A new tool or payload can alter mass distribution and shift the structural modes.
Lightweighting side effects
Material removal can improve mass and actuator requirements while reducing stiffness enough to create a new vibration problem.
The last case is particularly important during robotic arm design optimization.
A recent study combined topology optimization, modal analysis and experimental validation to investigate weight reduction and vibration performance in a robotic-arm component.
How to reduce robotic arm vibration
Once the dominant vibration mode has been identified, the design can be modified based on its physical cause.
Increase structural stiffness
Additional section depth, ribs or local reinforcement can increase stiffness.
The objective should be to place material where it has the greatest structural effect rather than simply increasing the thickness of the entire component.
Modify the geometry
Changing the cross-section or load path can shift the natural frequencies while controlling mass.
Change mass distribution
The position of motors, gearboxes, tools and other concentrated masses can influence the dynamic response.
Improve joint stiffness
If a joint is responsible for a dominant mode, increasing link stiffness alone may provide limited benefit.
The joint or interface may need to be redesigned.
Revisit lightweighting
If topology or shape optimization has reduced mass significantly, the updated design should be checked again for stiffness and modal performance.
Review the motion profile
In some cases, changing acceleration, jerk or operating speed can reduce excitation of a structural mode.
This is not always a substitute for mechanical redesign, but it can be part of the overall solution.
Robotic arm vibration analysis should be part of the design process
Waiting until a prototype shows excessive vibration can make a relatively simple engineering problem expensive.
By that stage, the design may already involve:
- Manufacturing tooling
- Machined components
- Purchased actuators
- Production fixtures
- Prototype assembly
- Physical testing
Changing the mechanical structure late in development can affect several of these areas.
A simulation-led approach can identify dynamic problems while the design is still flexible.
A practical workflow can be:
CAD model → structural FEA → modal analysis → excitation assessment → frequency-response analysis → design modification → re-analysis → prototype validation
Not every robotic arm requires every step.
The appropriate analysis depends on the robot’s speed, payload, reach, stiffness, precision requirements and operating environment.
Robotic arm vibration, stiffness and weight are connected
These three design variables should not be evaluated independently.
A heavier structure may provide greater stiffness but increase actuator requirements.
A very lightweight structure may reduce actuator load but become more flexible.
Increasing stiffness through geometry rather than simply adding mass may provide a better solution.
That is why a useful robotic arm optimization process considers:
Mass + stiffness + strength + natural frequency + operating loads
rather than optimizing only one variable.
For example, a topology-optimized component may achieve lower mass, but the redesigned component should then be checked for structural stiffness, natural frequencies and operating response.
The objective is not simply to make the arm lighter.
The objective is to achieve the required dynamic performance with the minimum practical structural mass.
Simulation and physical vibration testing
Simulation should ultimately be compared with physical behavior when the application requires a high level of confidence.
Experimental modal analysis can be used to identify the actual natural frequencies and mode shapes of the physical structure.
Comparing simulation and test results can reveal whether assumptions about:
- Material properties
- Joint stiffness
- Mounting conditions
- Concentrated masses
- Structural connections
are representative of the actual hardware.
Published robotic-arm research has used experimental testing to validate simulated modal behavior.
The purpose of this correlation is not simply to obtain matching numbers.
It helps improve the structural model so that subsequent design iterations provide more useful predictions.
When to use robotic arm vibration analysis during product development
Modal and vibration analysis is particularly valuable when:
- A new robotic arm architecture is being developed
- The arm has a long reach
- Low mass is a major design requirement
- The robot operates at high speed
- End-effector accuracy is critical
- A new payload is being introduced
- Prototype testing has identified unexpected vibration
- A lightweighting program has changed structural stiffness
- Static FEA passes but dynamic performance remains uncertain
- The robot is mounted on a flexible or moving platform
The earlier the analysis is introduced, the more design freedom the engineering team has.
What a robotic arm vibration analysis should deliver
A useful engineering analysis should go beyond a table of natural frequencies.
Depending on the project, the output can include:
- Natural frequencies
- Mode shapes
- Dominant vibration modes
- Structural deformation patterns
- Critical components
- Frequency-response results
- Stress and displacement response
- Operating-frequency comparison
- Design recommendations
- Updated simulation results after design changes
The important deliverable is the engineering decision.
For example:
Which component should be redesigned?
How much stiffness is required?
Will the proposed weight reduction create a new vibration problem?
Does the operating speed need to change?
Does the joint require additional stiffness?
These questions connect CAE results directly to mechanical product development.
Robotic arm vibration analysis as part of hardware engineering
For a robotics company, vibration analysis is rarely an isolated activity.
It normally connects with other parts of mechanical development:
CAD design → structural FEA → modal analysis → design optimization → prototype → physical validation
A change made for one requirement can affect another.
Reducing weight can affect stiffness.
Increasing stiffness can affect mass.
Changing the end effector can affect the dynamic response.
Changing the payload can shift natural frequencies.
This is why the most useful simulation work is performed as part of the broader hardware design process rather than as a standalone report.
Need robotic arm vibration or modal analysis?
Caliber Technologies can support robotics hardware development with structural simulation, FEA, modal analysis, vibration analysis and design optimization.
The analysis can be used to evaluate the mechanical design before prototype testing, investigate vibration problems in an existing design, or compare design alternatives during product development.
If your robotic arm is showing excessive vibration, resonance, poor settling behaviour or uncertain dynamic performance, the right starting point is to identify the structural mode behind the problem rather than simply adding material and hoping the vibration disappears.
Frequently asked questions
What is robotic arm vibration analysis?
Robotic arm vibration analysis evaluates how a robot structure responds to dynamic excitation. It can include modal analysis to identify natural frequencies and mode shapes, followed by frequency-response or harmonic analysis when forced vibration needs to be evaluated.
What is robotic arm modal analysis used for?
Robotic arm modal analysis is used to identify natural frequencies and mode shapes and determine whether structural resonances may overlap with operating excitation.
Can FEA predict robotic arm resonance?
FEA can predict natural frequencies and structural modes when the model, material properties, mass distribution, connections and boundary conditions adequately represent the physical system. Physical testing can then be used to validate the model.
Why does a robotic arm vibrate at certain speeds?
A particular speed or motion condition can generate excitation close to one of the structure’s natural frequencies. The resulting response can become significantly larger than it is at other operating conditions.
Does reducing robotic arm weight increase vibration?
It can. Reducing mass does not automatically create a vibration problem, but removing material can also reduce stiffness. The resulting change in the stiffness-to-mass relationship can shift natural frequencies and alter dynamic response.
Should modal analysis be performed before manufacturing?
For vibration-sensitive robotic hardware, performing modal analysis during design can help identify structural problems before manufacturing and reduce the risk of discovering resonance issues during prototype testing.
What is the difference between modal analysis and harmonic analysis?
Modal analysis identifies the natural frequencies and mode shapes of a structure. Harmonic or frequency-response analysis evaluates how the structure responds to a specified dynamic excitation across a frequency range.
Can robotic arm vibration analysis be combined with design optimization?
Yes. Modal analysis can be used alongside structural FEA and optimization to evaluate whether changes intended to reduce mass or improve stiffness also produce acceptable dynamic behaviour.